
June 18, 2026 | Articles 5 Views
A robot crash does not always destroy equipment. Sometimes the visible damage is minor. The larger cost appears later, when the robot no longer reaches the same path, the TCP no longer behaves as expected, the fixture reference has shifted, or the team has to decide whether to re-teach the cell from scratch.
For high-value robotic applications, recovery time can become more expensive than the original event. Production waits while technicians inspect the tool, confirm mastering, check frames, run test paths, and manually adjust points. In the worst cases, teams spend days trying to make the cell behave the way it did before.
The central question after a crash is simple: can the cell return to its known accurate condition without rebuilding the program point by point?
A crash, tool replacement, robot service, or fixture move can disrupt the physical assumptions behind the robot program. The program may be unchanged, but the physical system is no longer the same.
Post-event accuracy problems often come from:
Manual re-teaching can get a robot moving again, but it can also hide the root cause. If the robot-cell geometry has changed, re-teaching points may simply create a new local workaround. That workaround may solve today’s immediate path issue while creating future problems for offline programming, duplicated cells, inspection accuracy, or process consistency.
Manual recovery is especially risky when the original program was developed from CAD, simulation, or a validated production baseline. Once operators begin adjusting points manually, the relationship between the physical cell and the engineering model can weaken. The cell may run, but its digital foundation becomes less reliable.
A stronger recovery strategy starts before the crash. Manufacturers benefit when each robot-cell has a known calibrated baseline: robot parameters, frames, TCP assumptions, fixture relationships, and measurement references that define how the cell should behave when healthy.
After an event, the team can compare the current cell condition against that baseline. Instead of guessing which points changed, they can identify whether the problem comes from robot mastering, TCP shift, fixture movement, or another physical source.
This is where calibration-based recovery becomes valuable. It turns recovery from a manual search process into a measurement-led correction process.
Dynalog’s technologies are designed around the relationship between robot programs and real physical robot-cell geometry. DynaCal can support absolute robot-cell calibration and recovery of robot-cell parameters. DynaFlex can support in-line accuracy maintenance and compensation in demanding production environments. CompuGauge can support robot performance analysis when teams need to understand what changed.
In recovery scenarios, the goal is not simply to move the robot again. The goal is to restore confidence that the robot, tool, fixture, and program are aligned with the original manufacturing intent. That helps reduce re-teaching, shorten downtime, and protect validated programs.
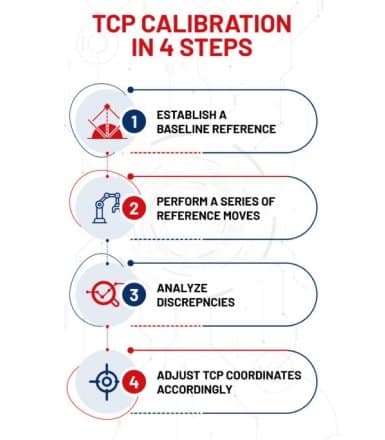
A disciplined recovery workflow reduces guesswork and helps teams avoid unnecessary program edits:
Calibration-based recovery is most valuable in cells where path accuracy directly affects quality, scrap, or customer compliance. Examples include laser cutting, sealing, welding, drilling, trimming, robotic inspection, aerospace assembly, and any process where manual touchup threatens validated quality.
For these applications, recovering the geometry of the cell is often more important than simply making the robot complete the cycle. The program needs to be correct, not merely functional.
Robot crash recovery should not depend entirely on manual re-teaching. When a robot-cell has a calibrated baseline and a measurement-led recovery process, manufacturers can reduce downtime, protect validated programs, and return the cell to its intended accuracy with greater confidence.
A. Robot crash recovery is the process of restoring a robot cell after a collision, tool impact, fixture shift, or service event so the robot program matches the physical system again.
A. Re-teaching can be slow and may create local workarounds instead of correcting the underlying robot, TCP, fixture, or frame error.
A. Teams should check robot mastering, TCP condition, fixture location, reference frames, tool mounting, and whether the current cell matches the calibrated baseline.
A. Calibration helps identify and correct differences between the robot-cell’s current physical condition and its intended accurate condition.
A. Yes. When a calibrated baseline exists, recovery can be faster because teams can diagnose what changed instead of manually searching through program points.
If one crash or fixture move can force hours of re-teaching, Dynalog can help you evaluate a calibration-based recovery strategy that protects uptime and validated robot programs.
June 15, 2025

January 20, 2026

August 27, 2025


We are committed to exceeding client expectations by delivering innovative, sustainable, and cost-effective construction solutions.
6001 North Adams Road,
Bloomfield Hills, MI 48304, USA


We collect cookies to analyze our website traffic and performance; we never collect any personal data.