Simulation/Offline Programming
Applied Manufacturing Technologies (AMT) began using ROBCAD for simulation and off-line programming of robotic cells in 1992. During the first few years of use of ROBCAD, AMT staff developed particular expertise in off-line programming of robotic paint cells where tolerances for position accuracy are not so demanding. A few years ago, in an effort to extend the use of off-line programming to welding and other applications, AMT investigated solutions using calibration systems and selected Dynalog Inc. as the calibration vendor AMT recommends for their off-line programming customers for many applications.
StellantisChrysler JR Program – Robot Swap at SHAP
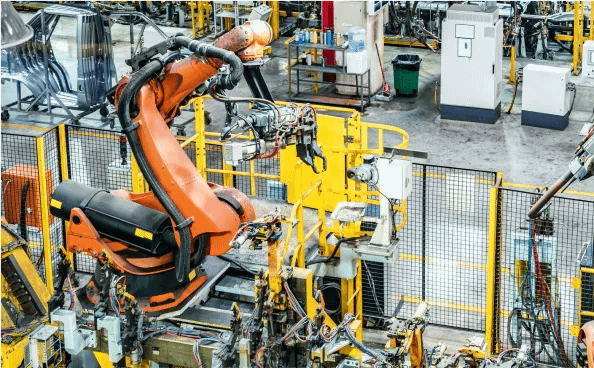
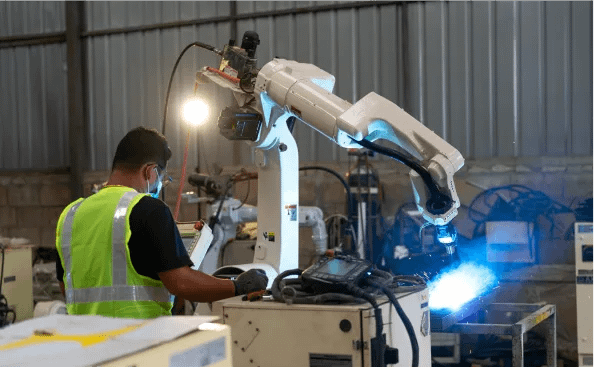
Recently, in anticipation of the launch of the JR program at the Sterling Heights Assembly Plant (SHAP), StellantisChrysler’s Advance Manufacturing Engineering group enlisted AMT and Dynalog to perform two types of robot program transfers:
- Robot Swap:
The transfer of existing production robot programs to new robots being installed at the plant; and
- Robot Cell Cloning:
The transfer of existing production robot programs between parallel production lines at the plant.
Both the Robot Swap and Robot Cell Cloning tasks were scheduled on a rolling basis to minimize production interruption by performing the tasks during weekend down-time. As a result, the time required to physically remove the existing robots and then commission the new robots left very little time for programming of the new robots yet the current production cycle time had to be maintained!
 As Dennis Archer of StellantisChrysler’s Advance Manufacturing Engineering stated at the 1999 NASCAPE Conference in Detroit, “We know that definitions of off-line programming vary throughout our industry. Our definition is quite simple: no ‘touch up’ with the teach pendant. The SHAP situation, as in any launch situation, required that we keep production interruption to an absolute minimum. Speed and accuracy of the calibration process were critical to our success. Because of the unique circumstances of our Robot Swap [between robots produced by different vendors], it was essential that we minimize risk by leveraging our past experience, StellantisChrysler’s and AMT’s, off-line programming thousands of the “old” and “new” robots using Tecnomatix’ ROBCAD software and Dynalog’s DynaCal™ System.”


 As Dennis Archer of StellantisChrysler’s Advance Manufacturing Engineering stated at the 1999 NASCAPE Conference in Detroit, “We know that definitions of off-line programming vary throughout our industry. Our definition is quite simple: no ‘touch up’ with the teach pendant. The SHAP situation, as in any launch situation, required that we keep production interruption to an absolute minimum. Speed and accuracy of the calibration process were critical to our success. Because of the unique circumstances of our Robot Swap [between robots produced by different vendors], it was essential that we minimize risk by leveraging our past experience, StellantisChrysler’s and AMT’s, off-line programming thousands of the “old” and “new” robots using Tecnomatix’ ROBCAD software and Dynalog’s DynaCal™ System.”